Brachistochrone
| Brachistochrone | |
|---|---|
| State dimension: | 1 |
| Differential states: | 3 |
| Discrete control functions: | 1 |
The brachistochrone problem (from Greek brachístos chrónos, "shortest time") is one of the founding problems of the calculus of variations, and serves as a classical benchmark in optimal control. This description is taken from [1].
First posed by Johann Bernoulli in 1696 as a public challenge, the problem asks for the shape of a frictionless curve connecting two fixed points in a vertical plane such that a particle released from rest at the upper point reaches the lower point in minimum time under gravity. As an optimal control problem, the system state consists of the horizontal position, vertical position, and speed of the particle, while the control is the instantaneous angle of the velocity vector with respect to the vertical. The terminal time is free and is the quantity to be minimised. The analytical solution is a cycloid, obtainable through Pontryagin's minimum principle or the classical Euler–Lagrange equations.
Mathematical formulation
where is the horizontal position, is the downward vertical position, is the speed of the particle, and is the angle of the velocity vector measured from the downward vertical. The speed dynamics follow from conservation of energy under gravity: . Note that , so the particle starts from rest.
Parameters
These fixed values are used within the model:
| Symbol | Value | Description |
|---|---|---|
| 9.81 | Gravitational acceleration (m s−2) | |
| 1 | Target horizontal position (m) | |
| 1 | Target downward vertical position (m) |
Reference Solutions
Here is one local solution to the above control problem.
- Reference solution plots
-
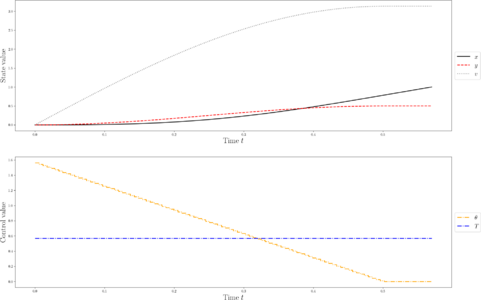 Optimal trajectory and control for the brachistochrone problem (cycloid solution).

Miscellaneous and Further Reading
The analytical solution is a cycloid: the locus traced by a point on the rim of a circle rolling along a flat surface. It can be parametrised as , , where the radius is determined by the boundary conditions. The brachistochrone problem is a standard example in textbooks on optimal control and the calculus of variations, and is used as a test case for direct transcription methods due to its free terminal time and the mild singularity at where the speed vanishes. This formulation and further discussion can be found in [1] and [2].
References
[1] Caillau, J.-B., Cots, O., Gergaud, J., & Martinon, P. OptimalControlProblems.jl: a collection of optimal control problems with ODE's in Julia. https://github.com/control-toolbox/OptimalControlProblems.jl
[2] Bryson, A. E., & Ho, Y.-C. (1975). Applied Optimal Control: Optimization, Estimation, and Control. Taylor & Francis.